
Gripper Project

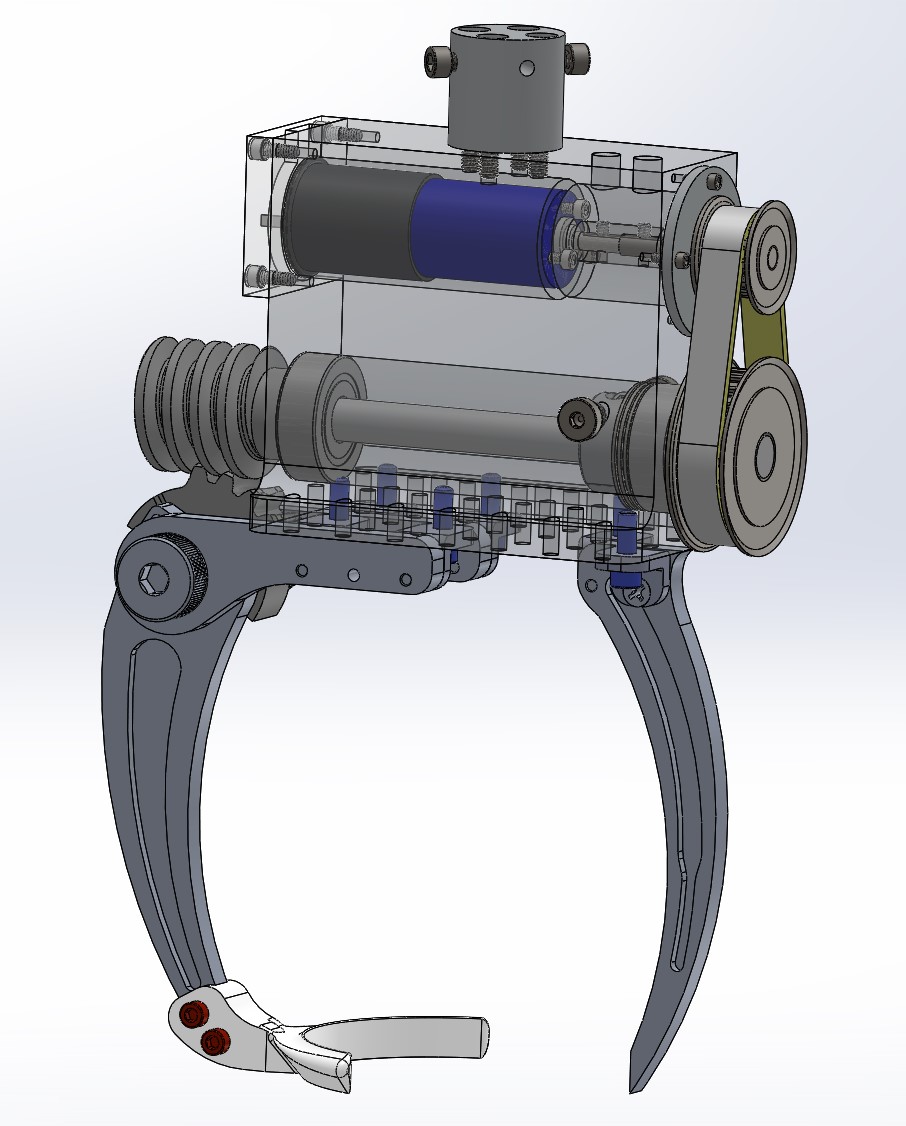
The objective of this Design 1 [24-370] project was to design and build an actuated gripper powered by a single motor which can grab a water bottle top with a weighted metal bottom. Once the object is firmly grasped by the gripper, the whole assembly is released from a 90-degree angle and allowed to swing for a period of time. Afterwards, the object’s position relative to its starting position is measured. If the object has displaced more than 0.1 inches in any direction the gripper would fail the test.
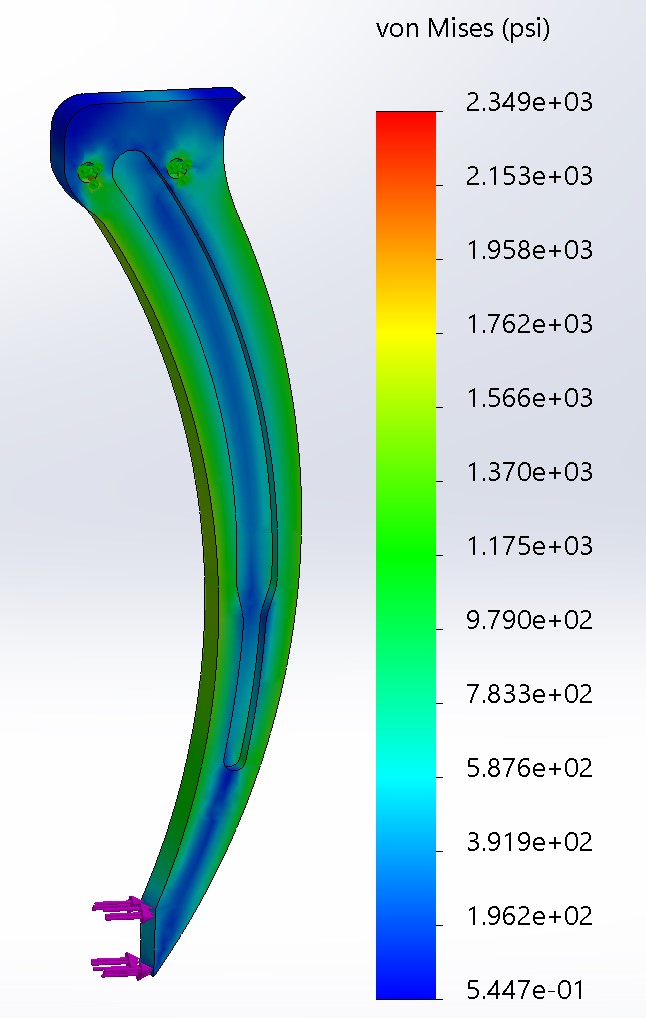
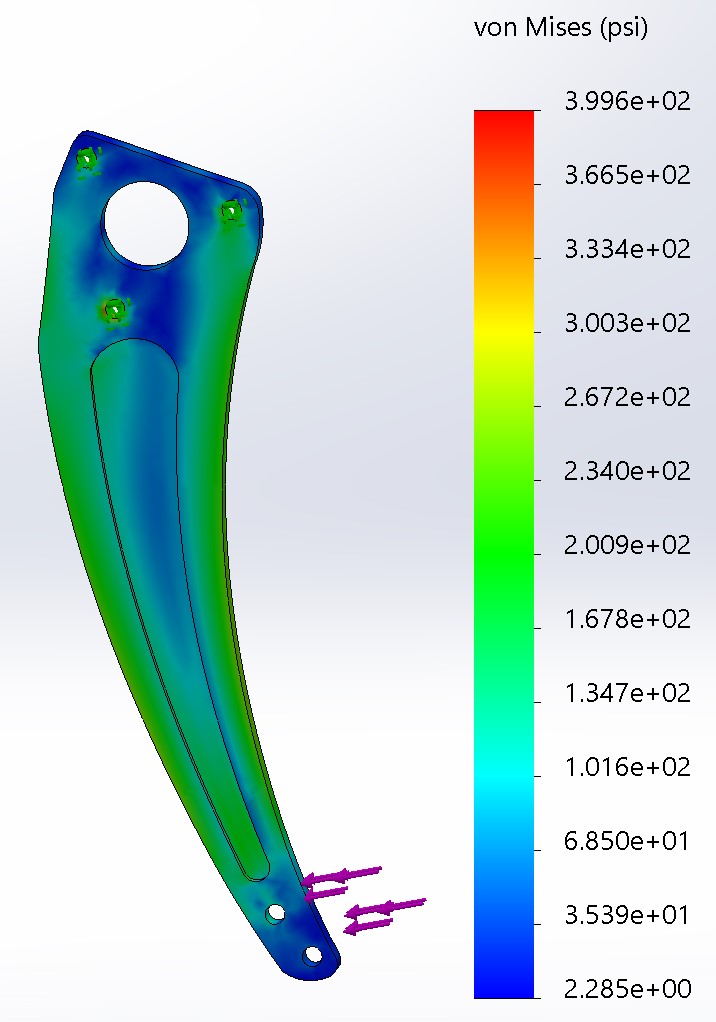
I was responsible for the design, CAD, and FEA. My teammates CNC cut the parts.
Back to Recent Work