
PCAMS NanoPiper
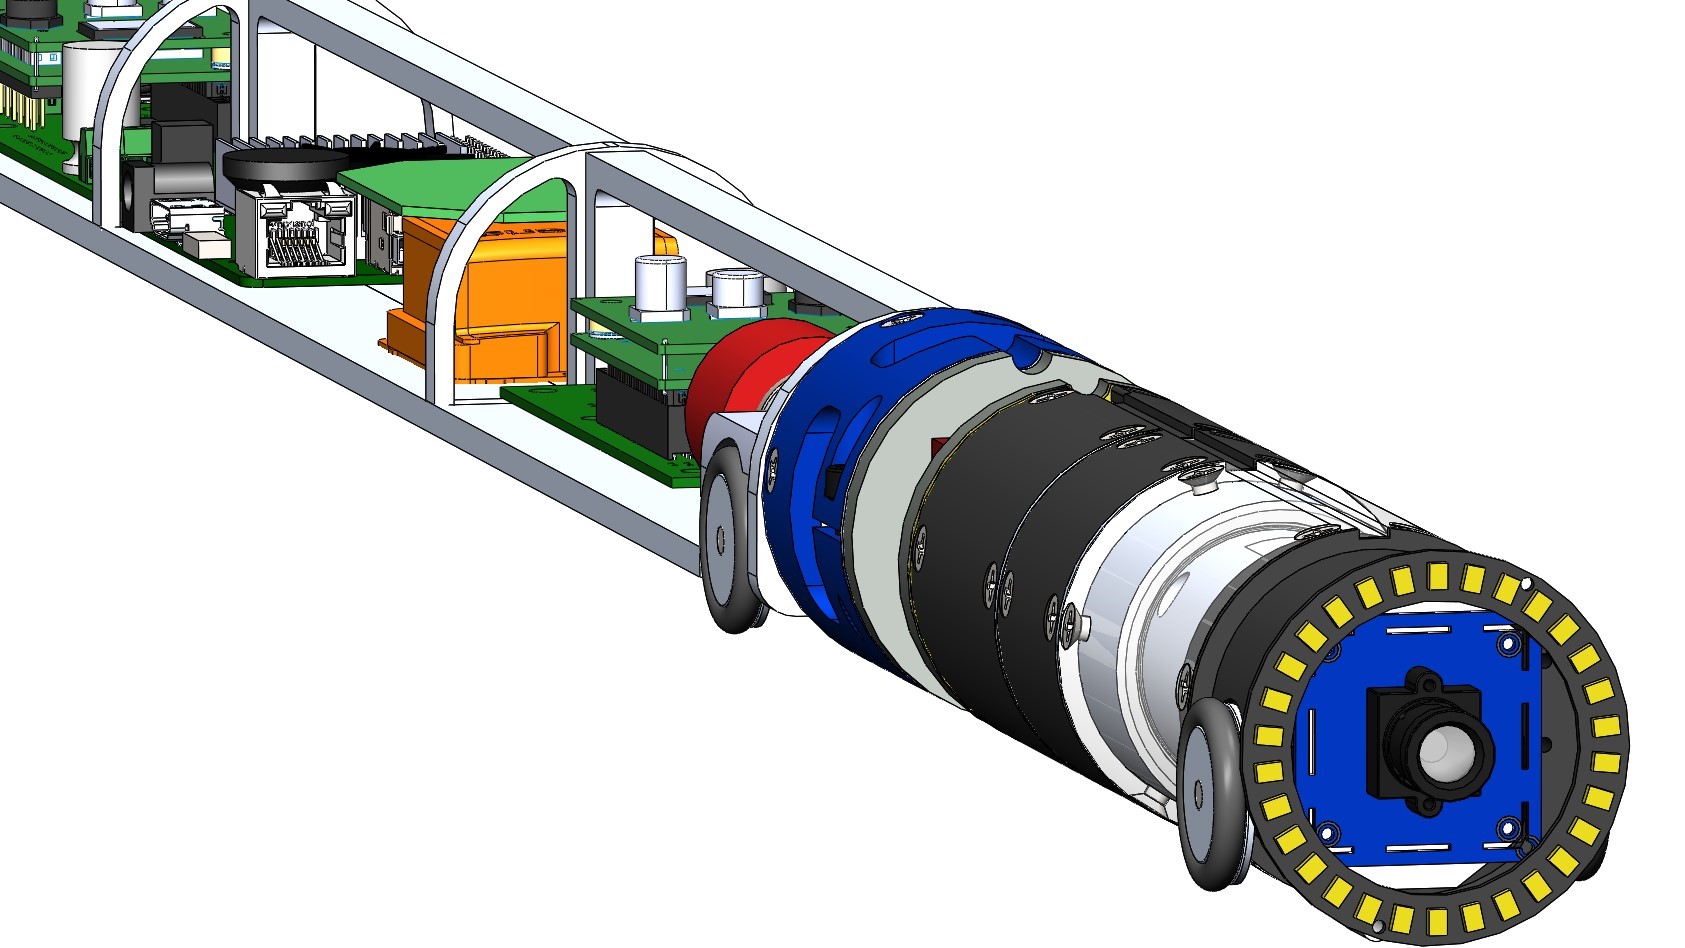
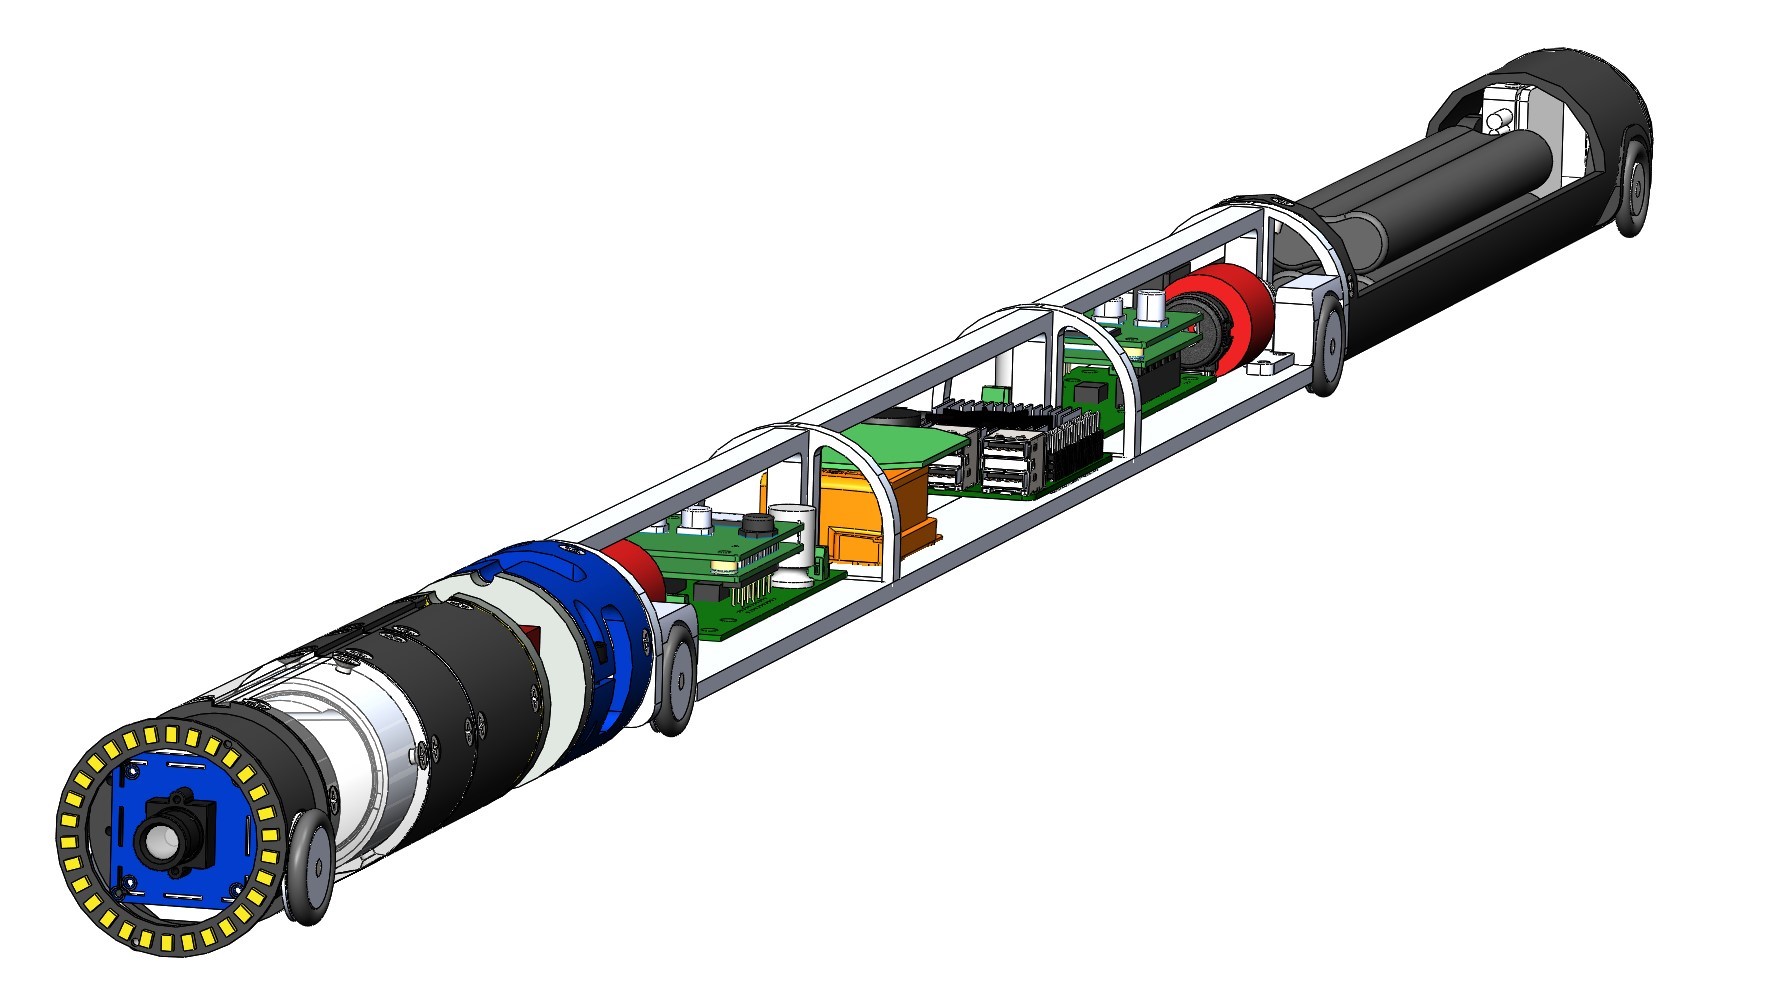
NanoPiper was one of many sizes of pipe inspection robots being developed by Carnegie Mellon's Nuclear Robotics Program. Led by Red Whittaker at the CMU Field Robotics Center, we prototyped a Pipe-Crawling Activity Measurement System (PCAMS) to traverse the smallest pipes in the Portsmouth Nuclear Facility.
NanoPiper is a prototype robot meant to accurately inspect the inside of 3"-5" pipes for radioactive deposit. If the detected radioactivity surpassed the DOE's threshold, the pipe would need to be removed prior to building demolition.
I assisted with the design of the frame of NanoPiper and modeled all electronics that did not have pre-existing CAD models from the manufacturer. Lastly, I developed simulated radioactive buildup for safe testing inside our calibration pipes.
PCAMS RadPiper WebsiteBack to Recent Work